Realizing Rapid Reduced-cost high-Risk Research
NASA’s Realizing Rapid, Reduced-cost high-Risk Research project, or R5, is a series of CubeSat technology demonstration missions intended to rapidly and affordably demonstrate a variety of technology prototypes in low Earth orbit (LEO). By accelerating the in-orbit demonstration of technologies developed by industry, academia, and government agencies including NASA, these technologies are more readily made available for use on NASA missions and beyond.
The ultimate objectives of the R5 series are to directly demonstrate many technology payloads to enable their adoption by end users, including NASA, and pioneer new approaches to build and operate spacecraft, reducing development-to-launch timelines from years to months, and reduce spacecraft costs by a factor of 10.
The spacecraft series uses an incremental development strategy where each spacecraft features improved performance over the previous. Each evolution of the spacecraft bus is suitable for a variety of payloads.
While each spacecraft is built around a primary payload and mission, the intent is to then add on as many secondary payloads and objectives as feasible.
R5’s processes rapidly and affordably deliver technology demonstration missions to space. The R5 team uses a minimal viable product approach which determines the simplest version of a spacecraft that can be built and released to deliver the intended functionality.
Each mission is designed to iterate quickly, reducing cost and schedule while improving capability over time. Additional R5 tenets include the use of commercial off-the-shelf hardware; streamlined documentation and processes that take advantage of frequent communication via collocation of the team; assembly, integration, and tests conducted in less-burdensome lab environment than cleanrooms (where possible); minimal environmental testing; thorough integrated functional testing; and consistent capture of lessons learned to feed insight into subsequent spacecraft builds.
Reviews are also streamlined and focus on sharing information meant to ensure that stakeholders concur that the mission concept is valid and that the completed spacecraft is acceptable.
The R5 project is managed and funded by NASA’s Small Spacecraft & Distributed (SSDS) within the agency’s Research and Technology Mission Directorate (RTMD) at NASA Headquarters in Washington. SSDS is based at NASA’s Ames Research Center in California’s Silicon Valley.
During the development of R5-S2 and R5-S4, SSDS became the primary stakeholder for the R5 mission series. The SSDS expands U.
S. capability to execute unique missions through rapid development and in-space demonstration of capabilities for small spacecraft applicable to exploration, science, and the commercial space sector.
The Engineering Directorate at NASA Johnson provides institutional Internal Research and Development (IRAD) funds to support the R5 series in addition to access to on-site facilities.
• Overcome the complexities of establishing a new process within the US government to enable advanced small spacecraft technology demonstrations at the lowest possible cost and on the fastest achievable schedule, with a goal of more than one mission per year. • Operate multiple technology demonstration payloads in LEO without levying traditional flight system requirements on the spacecraft.
• Advance technologies required for NASA’s In-space Servicing, Assembly, and Manufacturing capabilities.
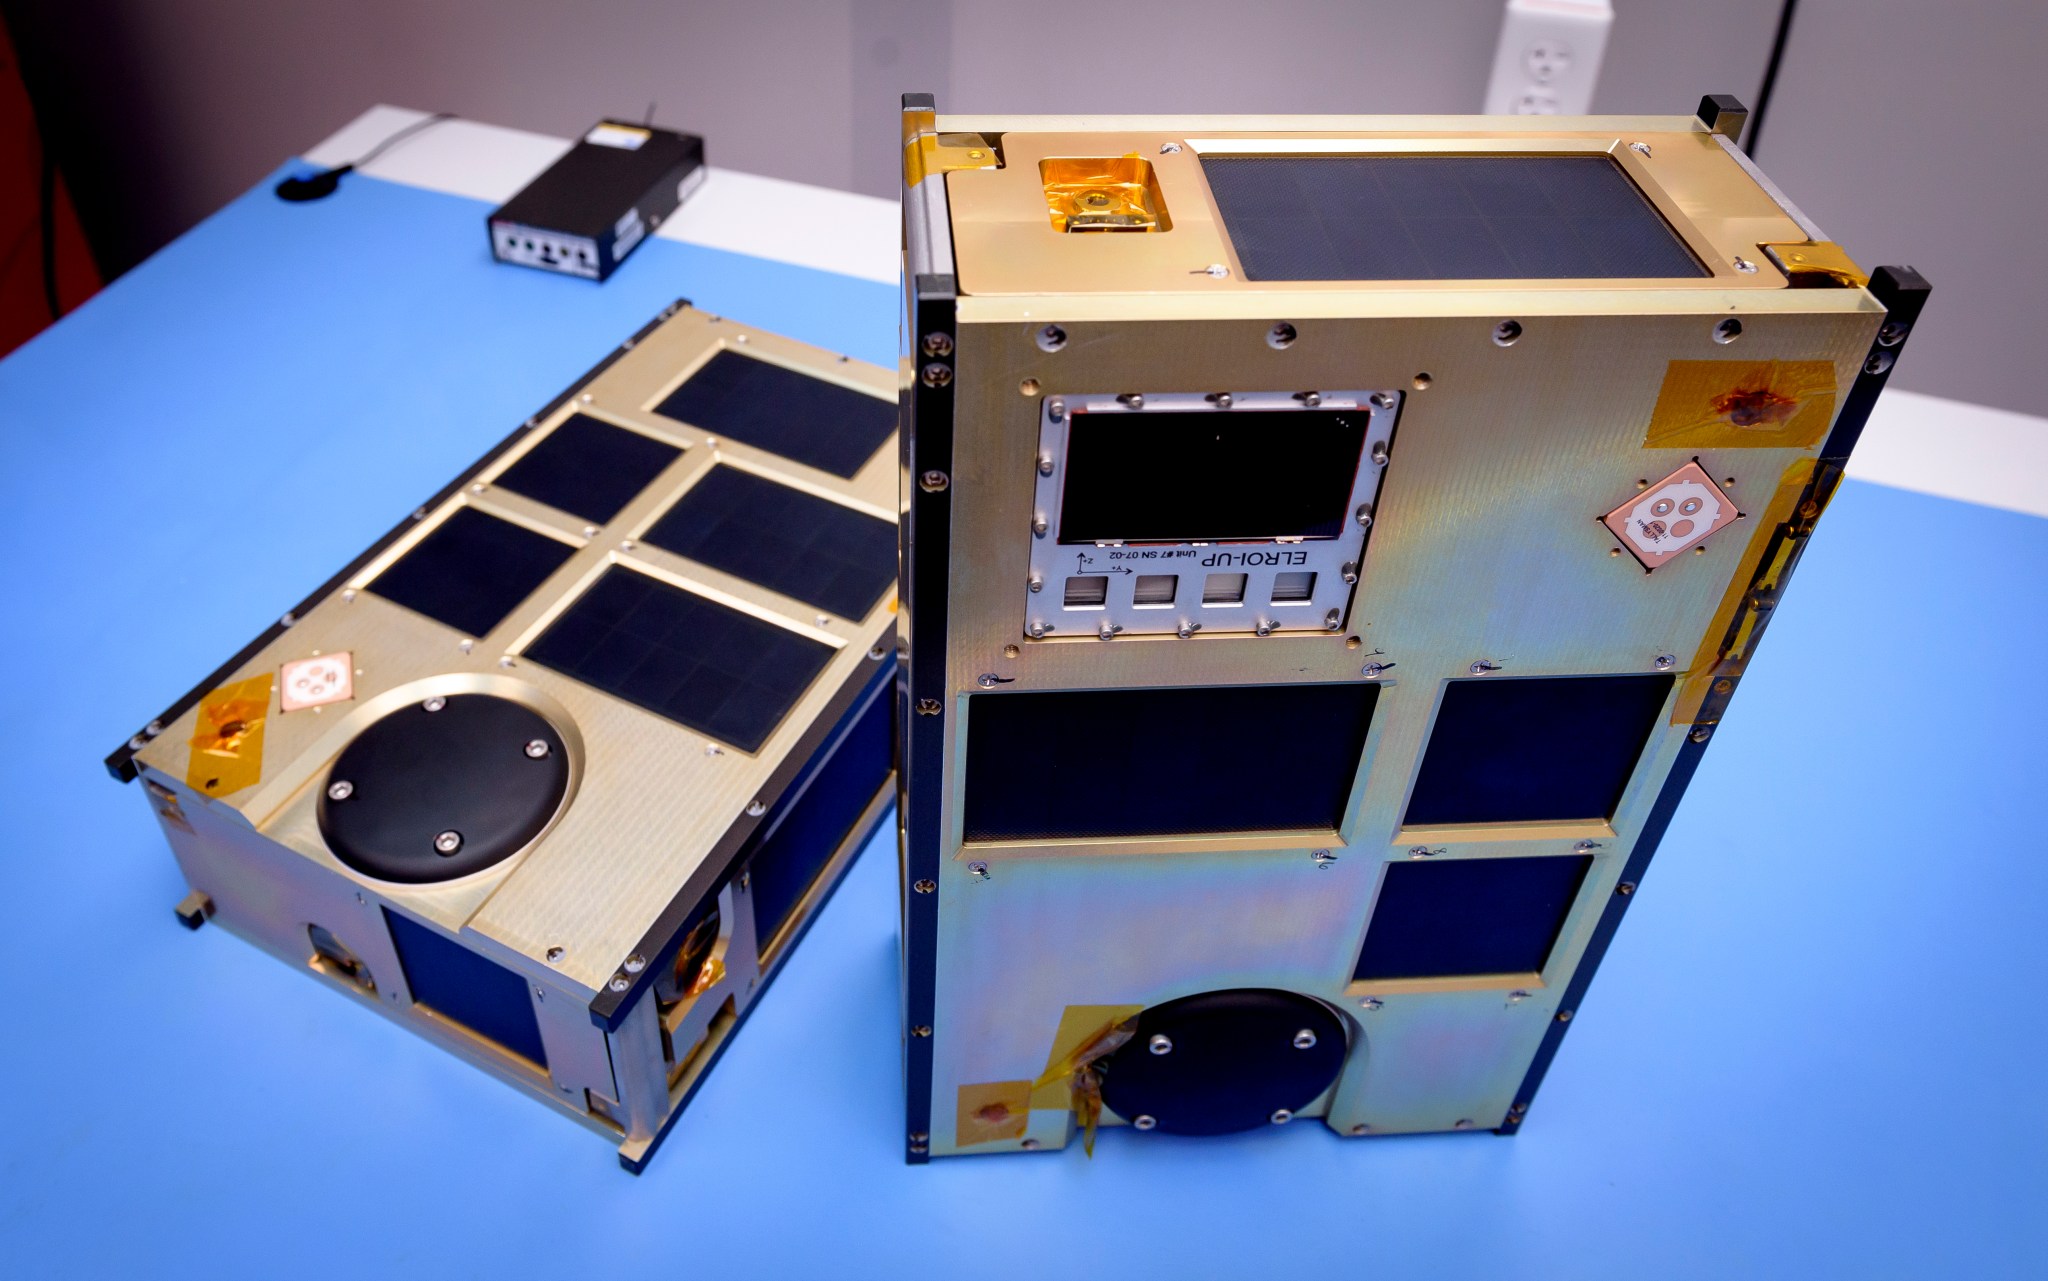
• A flexible 6U CubeSat platform provides approximately 3U—half the spacecraft volume—for technology payloads. • R5’s reconfigurable spacecraft bus supports a variety of payloads and missions, with capable computing, flight software, communications, and attitude control.
R5 promotes rapid, affordable spacecraft development through extensive use of commercial off-the-shelf hardware and streamlined testing processes. Commercially available components are screened to ensure suitability for the space environment.
• R5 is testing innovative technologies needed for exploration and deep space operations such as those for in-space inspection and assembly, spacecraft situational awareness, and navigation. • The R5 mission team actively pursues new public-private partnerships with industry and mission-focused partners across the US government.
• All spacecraft in the R5 mission series are developed and assembled at NASA Johnson with testing and integration occurring at both NASA Johnson and partner facilities. • NASA Johnson’s Seeker mission pioneered a rapid, low-cost approach to small spacecraft development that laid the foundation for the R5 spacecraft series, pushing toward a new US government process enabling frequent, affordable technology demonstration missions.
• The R5 mission team has collected more than 100 lessons learned and shares them in community forums and in technical papers. •
• R5-S1: Launched Feb. 10, 2022, as part of the NASA Educational Launch of Nanosatellites (ELaNa) 41 mission that launched on Astra’s LV0008 vehicle from Cape Canaveral Space Force Station in Florida.
The spacecraft did not reach orbit due to an upper-stage vehicle anomaly. • R5-S2 and S4: Launched July 4, 2024, as part of the ELaNa 43 mission that launched on Firefly Aerospace’s Alpha rocket from Vandenberg Space Force Base in California.
• R5-S7: Launched Nov. 28, 2025, aboard SpaceX’s Falcon 9 Transporter-15 from Vandenberg Space Force Base in California.
NASA awarded the launch services for S7 through its Venture-Class Acquisition of Dedicated and Rideshare (VADR) contract. NASA’s Launch Services Program, based at the agency’s Kennedy Space Center in Florida, manages the VADR contracts.
• R5-S10: Launched March 30, 2026, aboard a SpaceX Falcon 9 rocket from Space Launch Complex 4 East at Vandenberg Space Force Base in California as part of the company’s Transporter-16 commercial rideshare mission. • R5-S9: Launched July 7, 2026, aboard a SpaceX Falcon 9 rocket from Space Launch Complex 4 East at Vandenberg Space Force Base in California as part of the company’s Transporter-17 commercial rideshare mission.
• R5-S3, R5-S5, and R5-S6: Launch is anticipated no earlier than 2027.
Building off of the success of the Seeker mission, the R5 Spacecraft 1 (R5-S1) began development in 2021 as an internal research and development project at NASA’s Johnson Space Center in Houston. Made entirely from commercial off-the-shelf parts with a custom aluminum spacecraft structure, R5-S1 launched in February 2022, a mere eight months after the start of development.
However, due to a launch failure, R5-S1 did not reach orbit to perform its operations.
The R5 series traces some of its technologies and processes to the R5-S1 mission as many lessons were learned during its development, assembly, integration, and testing.
The R5 Spacecraft 2 (R5-S2) and R5 Spacecraft 4 (R5-S4) were the first two R5 spacecraft to successfully reach orbit. The spacecraft, both of which utilized nearly identical designs and neither of which contained any space-rated components, demonstrated the viability of the R5 process to rapidly and affordably deliver functional spacecraft to orbit despite the increased risk associated with R5’s ultra-lean processes.
Both spacecraft launched on July 4, 2024, on board the NASA Educational Launch of Nanosatellites (ELaNa) 43 mission flying on Firefly Aerospace’s Alpha rocket from Vandenberg Space Force Base in California. The spacecraft exceeded their minimum mission success criteria which included each spacecraft powering on, automatically starting operations, and transmitting telemetry to the ground.
The spacecraft also successfully performed many of their secondary objectives throughout a 10-month mission lifetime, including:
The R5-S4 hosted and successfully demonstrated an additional technology developed by Los Alamos National Laboratory (LANL) in Los Alamos, New Mexico. The Extremely Low Resource Optical Identifier (ELROI) technology is effectively a spacecraft license plate that allows for the independent identification of spacecraft from the ground, even if the spacecraft fails to power on or is otherwise unable to communicate.
The R5 Spacecraft 7 (R5-S7) launched on Nov. 28, 2025, on SpaceX’s Transporter-15 rideshare mission from Vandenberg Space Force Base in California.
The six-unit (6U) CubeSat, like R5-S2 and R5-S4 before it, followed the R5 approach to rapidly and affordably demonstrate technologies. The key experiment completed by R5-S7 during its mission was a controlled set of maneuvers around a client object, in this case, the upper stage of the Falcon 9 launch vehicle.
These maneuvers, performed immediately after S7’s deployment, are known as proximity operations. The spacecraft maneuvers were done using a novel propulsion system that utilized a commercially available tank made for paintball to store its propellant.
The spacecraft was able to identify and track the upper stage using a commercially available LiDAR sensor used in industrial and automotive applications, along with a commercially available camera. The ability to perform proximity operations is critical for inspection, servicing, and in-space assembly missions.
NASA’s R5 Spacecraft 10 (R5-S10) launched on March 30, 2026, on SpaceX’s Transporter-16 rideshare mission from Vandenberg Space Force Base in California. As part of this mission, R5-S10 and the Momentus Space Vigoride-7 orbital service vehicle conducted a joint in-orbit proximity operations technology demonstration.
Following deployment to low Earth orbit from the Vigoride-7 on Sept. 17, R5-S10 successfully operated as a free-flying inspection spacecraft, flying in formation with Vigoride-7, performing proximity operations, and capturing imagery of the orbital service vehicle to assess its health and performance.
The demonstration served as an important step in refining NASA’s in-space assembly and manufacturing capabilities and is essential for future autonomous space operations.
Additionally, R5-S10 supported a Momentus Space demonstration of the U. S.
Air Force Research Laboratory SpaceWERX’s Low-Cost Multispectral Rendezvous and Proximity Operations Sensor suite that is flying aboard Vigoride-7. The maneuvers by R5-S10 enabled collection of optical and lidar data at varying distances and under multiple lighting conditions.
The data collected by the sensor suite tracked and characterized R5-S10 throughout the operation. This sensor system will improve spacecraft situational awareness, relative navigation, and is important for autonomous satellite servicing and space debris management.
The mission also tested Wi-Fi-based inter-satellite communications, enabling R5-S10 to transfer large data files to Vigoride-7 for relay to researchers on the ground. Together, these demonstrations aim to advance technologies needed for future in-space assembly and manufacturing missions.
Finally, R5-S10 hosts an event camera payload for the Safe and Precise Landing Integrated Capability Evolution (SPLICE) project developed by NASA Johnson. An event camera is a new type of camera that can track changes in its field of view rather than capturing the whole picture, allowing it to track very fast and very faint objects.
The R5 Spacecraft 9 (R5-S9) launched on July 7, 2026, on SpaceX’s Transporter-17 rideshare mission from Vandenberg Space Force Base in California. R5-S9’s primary mission is operating a radiation detection, edge compute, and artificial intelligence (AI) anomaly detection payload developed by Sandia National Laboratories at Kirtland Air Force Base in Albuquerque, New Mexico.
R5-S9’s secondary objectives include the first flight of a low-cost size, weight, and power (SWaP) Optical Communications Transmitter developed by The Aerospace Corporation of El Segundo, California. This mission demonstrates the use of commercial off-the-shelf, high-performance compute for AI applications at the edge and novel technologies to downlink large amounts of spacecraft data without adding further congestion to the limited radiofrequency spectrum.
The R5-S3 and R5-S5 spacecraft are planned as the mission series’ second dual launch of R5 spacecraft. The spacecraft are each a different size with R5-S3 being the smaller of the two in the three-unit (3U) CubeSat form factor, and R5-S5, a 6U, being about twice as large.
Planned for launch no earlier than 2027, these spacecraft will demonstrate a number of technologies. R5-S5 will demonstrate all the technologies listed below while R5-S3 will demonstrate the first four.
Spacecraft 6 (R5-S6) and other R5 spacecraft, currently in development, continue to build on lessons learned from previously demonstrated R5 spacecraft as well as perform their own technology demonstrations.
Primary technology demonstrations planned for S6 include:
The R5-S6 and future spacecraft are scheduled to launch on a variety of launch vehicles in 2027.
Small Spacecraft Systems Virtual Institute (S3VI)
RTMD Small Spacecraft & Distributed Systems (SSDS)
Seeker Overview and Mission 1 Review– A New Development Approach for In-Space Inspectors (Seeker 1)
NASA’s Next Small Satellite Launch Set for January (R5-S1)
NASA’s ELaNa 43 Prepares for Firefly Aerospace Launch (R5-S2 and R5-S4)
NASA Cost-Saving Technology Demo is Ready for Launch (R5-S10)
NASA CubeSats Advance Space Weather, Tech Research (R5-S10)
NASA Tech and Science Bound for Low Earth Orbit on Commercial Launch (R5-S10)
NASA CubeSat to Speed Technology Testing in Orbit (R5-S9)
LANL of Los Alamos, New Mexico, provided the Extremely Low Resource Optical Identifier (ELROI) integrated on S1.
Demonstrated spacecraft commanding over the Iridium network
Demonstrated the functionality of a cold gas propulsion system
Validated environmental assumptions and hardware robustness
Imaged and downlinked the imagery of a resident space object – the launch vehicle’s upper stage after R5-S2 and R5-S4 deployment
LANL provided the ELROI technology demonstration on S4.
Martian Sky Relative Pose Estimation and 3D reconstruction algorithm is provided by Martian Sky Industries in Cleveland Heights, Ohio.
Momentus Inc., of San Jose, California, provides the Vigoride-7 Orbital Service Vehicle used to deliver S10 spacecraft to LEO.
Momentus has been selected to perform for the Air Force Research Labs SPACEWERX organization, which is the innovation arm of the U.S. Air Force.
NASA Johnson’s Safe and Precise Landing Integrated Capability Evolution (SPLICE) project provides the SPLICE event camera.
Sandia National Laboratories provided the radiation detection, edge compute, and AI anomaly detection software.
The Aerospace Corporation provided the low-cost low SWaP Optical Comm Transmitter.
Re-flight of LANL’s ELROI spacecraft license plate successfully flown on R5-S4
Martian Sky’s computer vision software called Client-Orientated Vision-Enhancing Recognition Technology (COVERT) will demonstrate stitching together 3D images in real-time to generate a 3D model of observed objects around the S3 and S5 spacecraft. This enables the spacecraft to understand the position of the objects, even without prior knowledge of them, bridging a necessary gap toward autonomous interaction with other spacecrafts and objects.
NASA’s Ames Research Center in California’s Silicon Valley provided Opportunistic Software Experiments for Spacecraft Autonomy Testbeds (OSE-SAT) software and in-space testbed for experimental software.
NASA’s Goddard Space Flight Center in Greenbelt, Maryland, provided OnAIR Software capable of autonomously identifying anomaly data in imagery.
University of California Davis in Davis, California, providedEVA handrail imager payload and ultra low-cost reaction wheel.
Astroscale US Inc., of Denver, Colorado provided a docking plate to enable a low-risk proximity operations target.
LANL provided the ELROI spacecraft license plate technology to be demonstrated on S3 and S5. This technology was earlier demonstrated on S4.
NASA Ames provided Opportunistic Software Experiments for Spacecraft Autonomy Testbeds (OSE-SAT) software and in-space testbed for experimental software.
NASA Goddard providedOnAIR Software capable of autonomously identifying anomaly data in imagery.
University of California Davis providedEVA handrail imager payload and ultra low-cost reaction wheel.
Astroscale US Inc. provided a docking plate to enable a low-risk proximity operations target.
The Optical Deep-space Instrument for Navigation (ODIN) and Target and Range-adaptive Optical Navigation (TRON) technologies will jointly demonstrate the next generation optical navigation system that can operate autonomously in orbits around Earth and at the Moon. Working together, the ODIN/TRON system will demonstrate various image processing techniques to include in-flight dual-camera calibration. The technology duo will also estimate spacecraft position via measurements of the lunar horizon or through optimal triangulation methods involving measurements of unresolved planetary bodies, as well as spacecraft attitude via stellar measurements.
A novel fluid measurement system that tracks propellant levels in microgravity called Modal Propellant Gauge (MPG) will also be demonstrated.
The ODIN demonstration is funded by NASA’s SSDS University SmallSat Technology Partnerships initiative.
The TRON demonstration is funded by NASA’s RTMD Early Career Initiative and by NASA Johnson through center IRAD funding.
The MPG demonstration is sponsored by NASA Johnson through center IRAD funding.